Robotics & Autonomous Systems Engineer
I build reliable robot software from sensing to motion. My work spans ROS 2, SLAM, Nav2, embedded systems, visual perception, manipulation, and reinforcement learning for humanoid control.
I earned a B.Eng. in Robotics and Mechatronic Systems Engineering from the University of Detroit Mercy with a 3.70/4.00 GPA and am continuing there in the M.Eng. program. Before UDM, I studied Mechanical Design, Manufacturing, and Automation at Beijing University of Chemical Technology.
I am actively seeking full-time roles in robotics, autonomous systems, embedded robotics, and robot learning.
GitHub · LinkedIn · Download CV
🔥 News
- 2026.05: Graduated from the University of Detroit Mercy with a B.Eng. in Robotics and Mechatronic Systems Engineering.
- 2026.05: Completed the Milk Dragon ROS 2 autonomous ground vehicle and validated its mapping and navigation stack.
- 2025.05: Won First Prize at RoboCup@Home China Open.
- 2024.07: Joined State Grid Intelligence Technology Co., Ltd. as a hardware and software engineering intern.
📝 Selected Projects
PPO Variants for Humanoid Motion Tracking · Sep. 2025 - Nov. 2025
Xianglei Dong
- Trained and evaluated five PPO variants for motion tracking on a 23-joint Unitree G1 humanoid using NVIDIA Isaac Lab and Isaac Sim.
- Reproduced PPO and Delta Action PPO baselines, then developed an optimized residual-policy variant that decoupled baseline and residual networks to reduce gradient conflicts.
- Achieved a mean reward of 5.03 with a coefficient of variation of 0.068; completed 6,000 iterations in about 2.5 hours on an RTX 4090.
Footage: cropped and enlarged recording of an early Isaac Gym evaluation run. The later experiments described here were conducted in Isaac Lab.
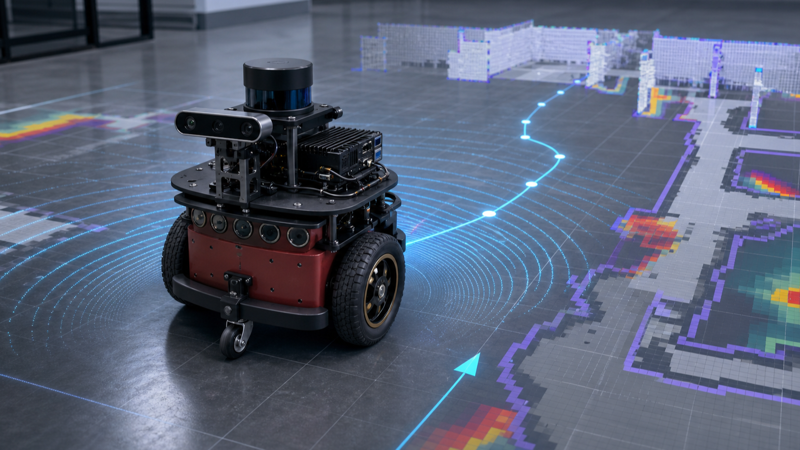
ROS 2 Autonomous Ground Vehicle for IGVC · Team Lead and Core Autonomy Developer, Aug. 2025 - May 2026
Xianglei Dong, Kaisheng Zhang, Boyi Zhang, Boni Zhang
- Led development of the Pioneer 3DX autonomy stack in ROS 2 Humble. I owned mapping and localization with SLAM Toolbox, Nav2 integration and DWB tuning, frontier exploration, TF and motion-control integration, and maintenance of the ROS 2 Pioneer driver.
- Teammates separately owned the E-stop, camera-perception, and LiDAR modules, then integrated the modules and tuned the final task-execution workflow.
- Resolved TF latency, SLAM queue saturation, and lifecycle startup issues. Validation reached -0.077 s TF delay, zero SLAM frame drops, 12.4 cm mean point-navigation error, and a stable 10.5 Hz command loop.
Image: project concept visualization.
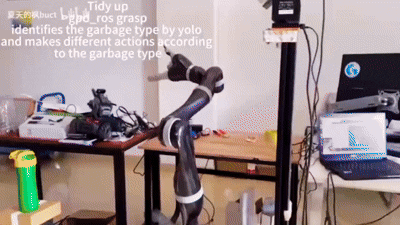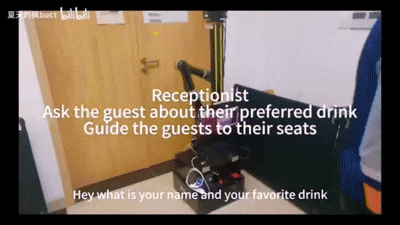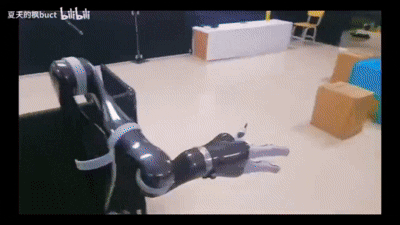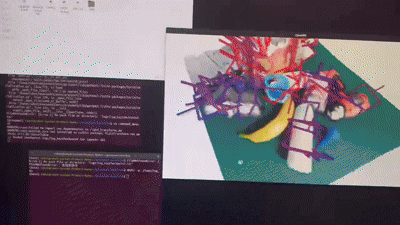
Intelligent Home Service Robot Based on ROS · Feb. 2024 - May 2025
Jiawei Xia, Xianglei Dong, Wengcong Zhang, Boyi Zhang, Yutong Sun
- Developed a Kinova Gen2 and Azure Kinect service robot for guest reception, voice interaction, recognition, navigation, cleaning, and manipulation.
- Integrated Azure AI Speech with a finite-state machine; used Cartographer, IRIS LaMa, DWA, and A* for mapping, localization, and planning.
- Connected YOLOv8 3D perception and GraspNet 6D grasp generation to the ROS manipulation stack.
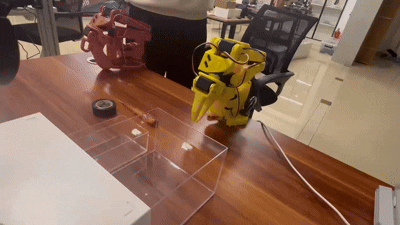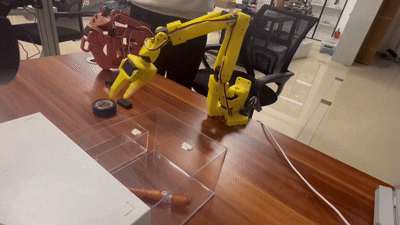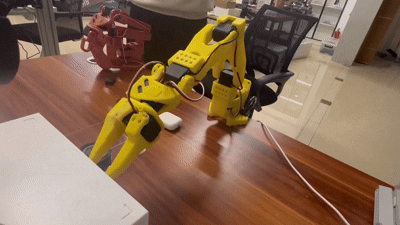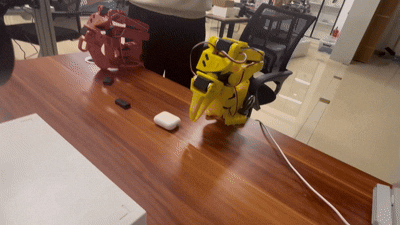
Reproducing and Training ACT from the LeRobot Project · Nov. - Dec. 2024
Jiawei Xia (equal contribution), Xianglei Dong (equal contribution)
- 3D printed, assembled, and brought up a leader-follower robotic arm platform for imitation-learning experiments.
- Reproduced the ACT training pipeline, collected a custom dataset, and trained the arm to organize objects on a desktop.
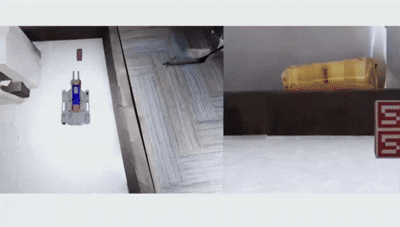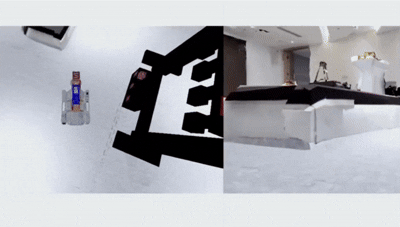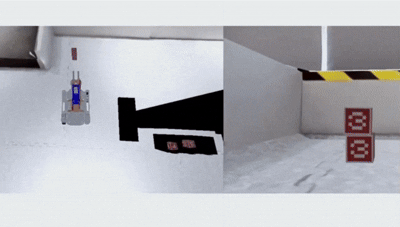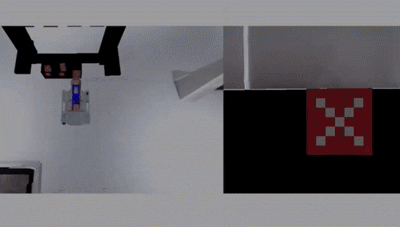
ICRA RoboMaster University Sim2Real Challenge 2024
Jiawei Xia, Xianglei Dong, Wengcong Zhang, Boyi Zhang
- Estimated box poses from ArUco detections and extracted transformation and rotation matrices.
- Combined an Extended Kalman Filter with an omnidirectional robot to improve localization and pose estimation.
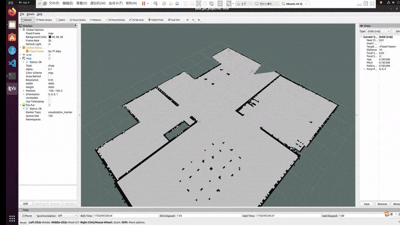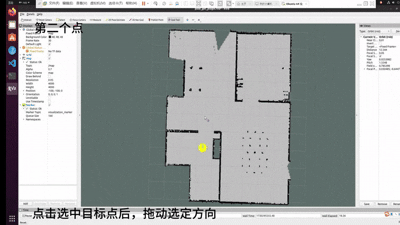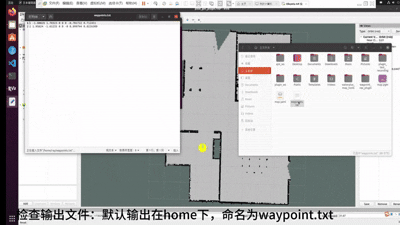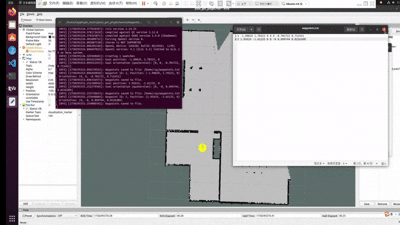
RViz Plugin for Multi-Point Navigation
Xianglei Dong
- Developed a custom RViz tool that records selected goal poses and visualizes them in the navigation interface.
- Implemented automatic multi-point traversal to remove repetitive manual coordinate entry during robot tests.
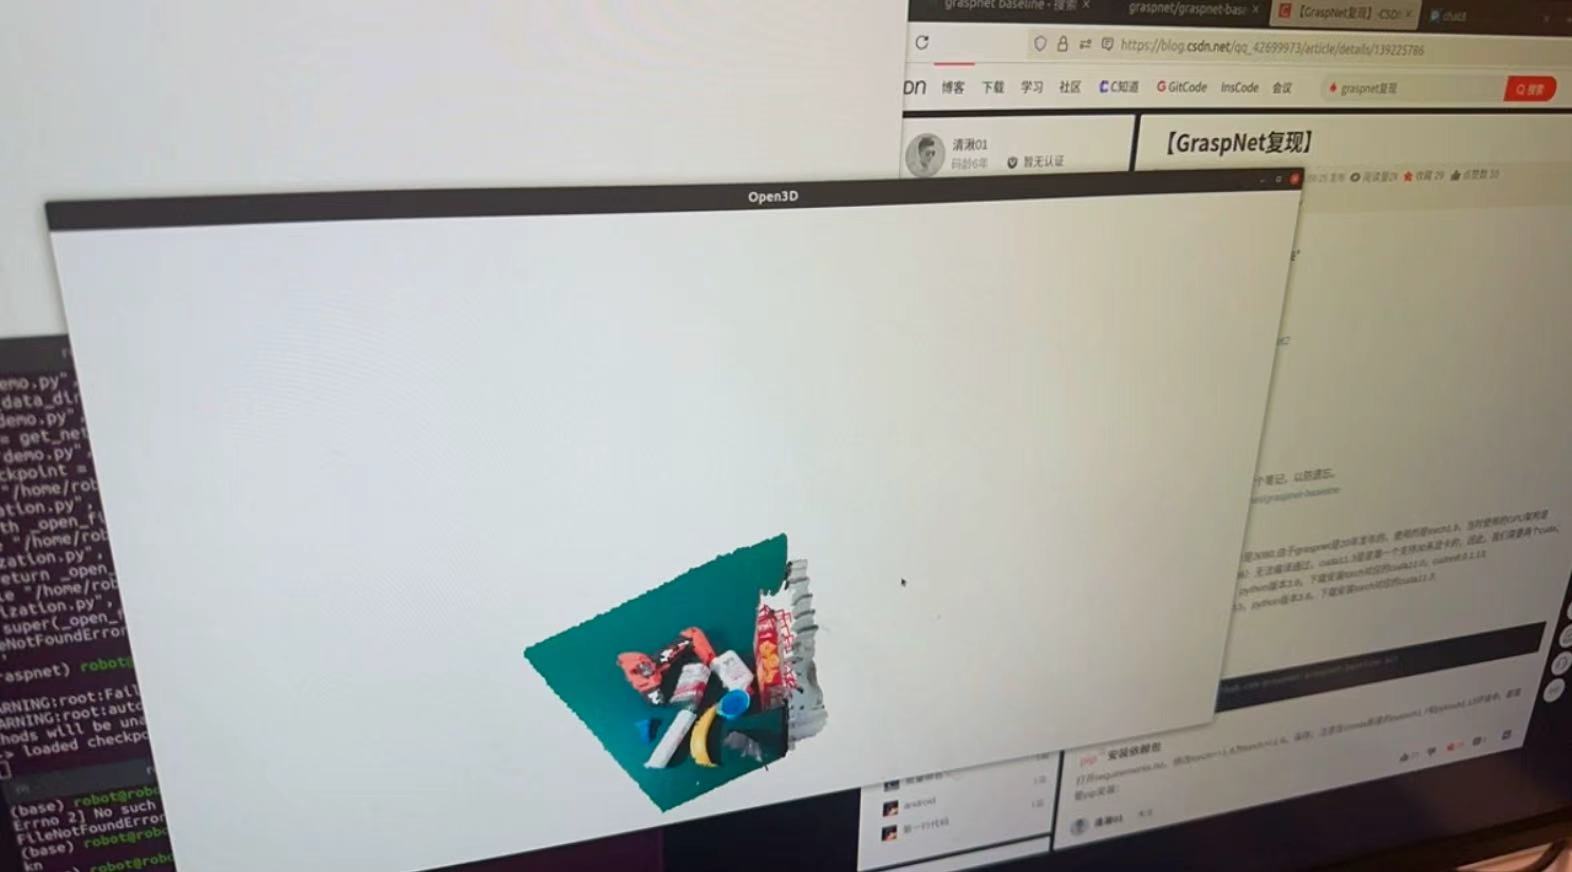
Xianglei Dong
- Built a ROS perception pipeline that combines YOLOv8 object detection with GraspNet 6D grasp-pose generation for robotic manipulation.
Xianglei Dong
- Developed a ROS Noetic pipeline that combines YOLO detections with depth data to estimate 3D bounding boxes and object poses for navigation and manipulation.
🏅 Honors and Awards
- 2025.05: First Prize, RoboCup@Home China Open.
- 2024.11: Second Prize, ICAN International Contest of Innovation.
- 2024.05: Second Prize, RoboCup@Home China Open.
📖 Education
- Aug. 2026 - Present: M.Eng. in Electrical and Computer Engineering (ECE), University of Detroit Mercy, Detroit, MI. Robotics and autonomous systems focus.
- Aug. 2025 - May 2026: B.Eng., Robotics and Mechatronic Systems Engineering, University of Detroit Mercy, Detroit, MI. GPA: 3.70/4.00, Dean’s List.
- Sep. 2022 - Jul. 2025: B.Eng., Mechanical Design, Manufacturing, and Automation, Beijing University of Chemical Technology, Beijing, China. GPA: 3.60/4.33.
💻 Experience
- Jun. 2024 - Sep. 2024: Hardware and Software Engineer, State Grid Intelligence Technology Co., Ltd., Jinan, China. Worked on robot hardware/software architecture, sensor and actuator integration, RTOS communication, calibration, and system-level debugging.